Submitted Oct 05, 2026
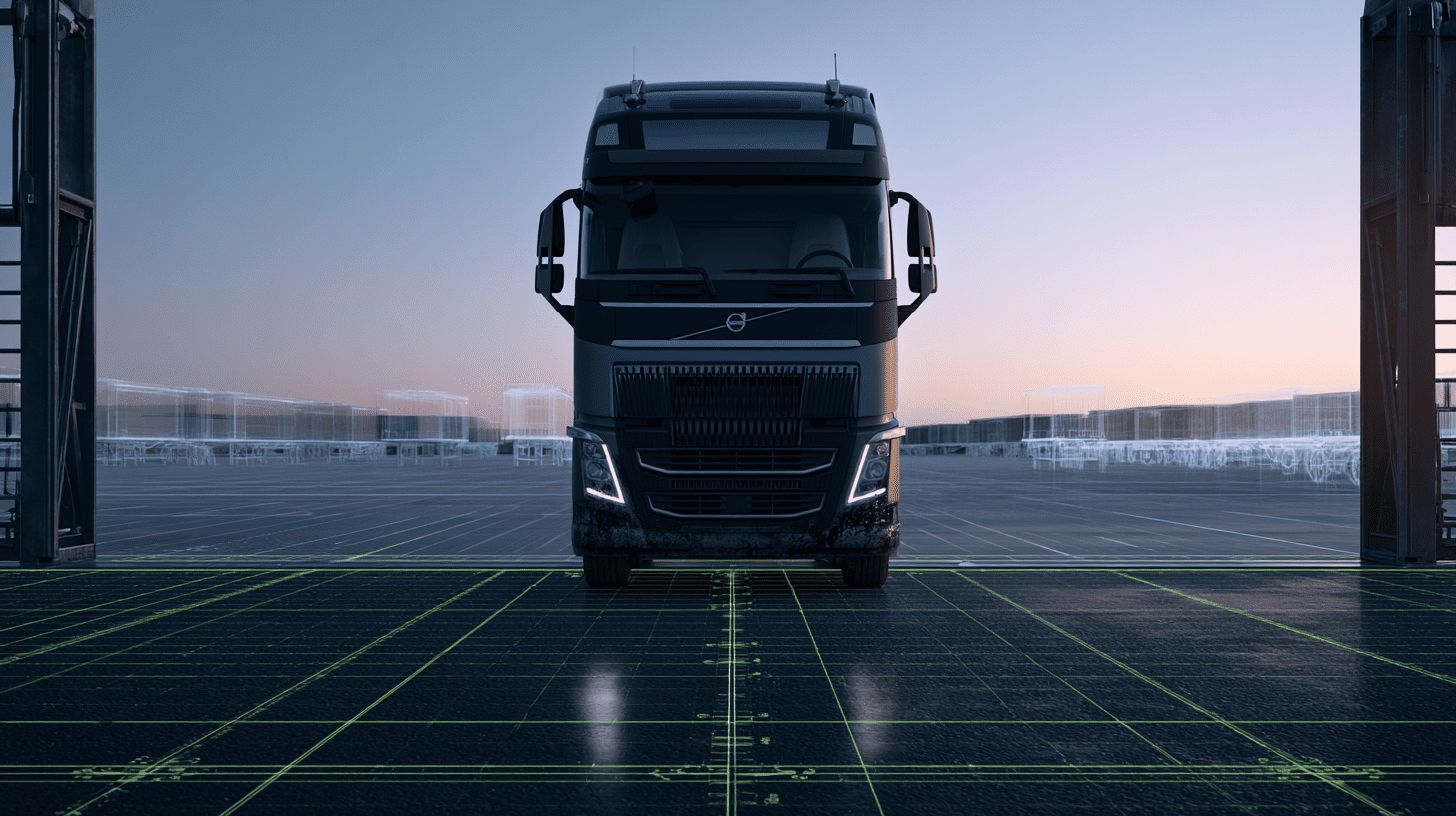
The assumption running through most conversations about autonomy in logistics is that the trucks are the hard part. Solve driverless over the road, and the facilities they arrive at will adapt.
It is the wrong way round. Point-to-point driving on mapped highways is the constrained problem. The yard is the unconstrained one, and it is where an autonomous vehicle stops being useful the moment it turns off the road.
Chris Brumett, Chief Product Officer at Terminal Industries, makes the point with an example everyone has now seen in person.
Why a Waymo in Your Yard Is Not the Same Problem
"You go to a major city, you'll see them mapping around," Brumett says of autonomous taxis. "And you look at them and they can navigate on over streets, they can even navigate inside parking lots and back up and look for things. But you've got to remember, they're not pulling a 53-foot trailer."
Two things separate the two situations, and both matter.
The first is the vehicle. A tractor with a 53-foot trailer has a turning geometry, blind spot profile and reversing behaviour that has nothing in common with a passenger car. Backing a trailer into a dock at an angle is a skill human drivers take years to acquire.
The second is the environment, and it is the larger issue. "When you look at autonomous vehicles going from point A to point B, it's a more defined area," Brumett says. "Once they arrive at the facility, there's all kinds of variability."
Nobody has mapped your yard. There is no fleet of vehicles that has driven it ten thousand times to build a model of it. Trailer positions change hourly, staging areas move with volume, and the layout is not in any public dataset. The autonomous vehicle arrives at the gate having solved the well-mapped part of its journey and enters the part nobody has instrumented.
Brumett's framing for what that variability does to a plan is worth keeping: "Everybody's got a plan until they get hit in the face. And you've got to look at these variability of processes as that punch in the face."
What Actually Has to Be True First
The fleet is not homogeneous and will not be for a long time
The scenario in the marketing material is a facility where every arriving vehicle is autonomous. That is not the transition anyone will actually live through.
"One of the factors that we all have to solve as an industry is how to handle heterogeneous fleets," Brumett says. "It's easy when you have a fleet full of these autonomous trucks. Things would be fairly straightforward, you could figure it out. But the reality is that most operators aren't dealing with a homogeneous fleet. And that's where the tech has to be able to manage that kind of physical asset when you're not really sure what's going to come in and where it's coming from."
The number of distinct carriers serving a typical facility runs from single owner-operators with one power unit to major asset-owning fleets. Every one of them arrives with different equipment, different technology on board, and different levels of integration. A yard system that works only when every arrival is autonomous is a system that works never.
The gate has to be able to talk to a vehicle, not a person
This is the immediate, unavoidable blocker, and it arrives before any of the others.
Every element of a conventional gate assumes a human in the cab: someone to hand over documentation, answer a question, and be verbally directed to a destination. Remove the driver and there is no path through. The truck cannot present paperwork to a guard, and the guard has no way to tell it where to go.
Brumett describes the requirement as establishing a digital handshake at the point of entry: something that connects what is arriving to what the facility is expecting, without a person in the middle. That in turn depends on whether the documentation is genuinely machine-readable. "We have EDI transactions and APIs that can deliver the information," he says, "but is it detailed enough to provide the detail-level information that's needed to truly automate that process through, because there's no longer a human to hand another human a piece of paper."
Which is the whole problem in one sentence. The paper handover is load-bearing, and almost nobody has noticed.
Sensing and bandwidth come before robots
The least glamorous prerequisite is the one that stops most deployments.
Brumett uses a domestic analogy. As you add streaming services and connected devices at home, the bandwidth requirement climbs. The same applies to a facility, except the consequences are operational rather than a buffering video. "In order to leverage technology, you have to look at: is your infrastructure there to support it?"
Autonomous movement in a yard requires devices that can communicate continuously, which requires coverage across an outdoor site that was never wired for it. It also requires sensing on infrastructure that has historically had none. "As you start thinking about autonomously moving things around the yard, you need to start thinking about how are my dock sensors, how are my restraints going to know when to release and when to lock."
Dock restraints are a good example of the gap. A human driver sees a light and knows whether it is safe. An autonomous system needs the restraint itself to report its state. That sensor does not exist at most facilities, and no amount of vehicle autonomy compensates for its absence.
Robots are not one category and should not be evaluated as one
Terminal's team is publicly split on this, which makes the discussion more useful than a vendor consensus would be.
Brumett is sceptical of the humanoid scenario specifically. "I don't envision that there's going to be humanoids walking around the yard. I mean, the whole purpose of lights-out is that nobody's walking the yard, human or non-human."
That is a sharper argument than it first appears. If the objective is removing people from the yard, a machine shaped like a person is solving for a constraint you were trying to eliminate.
On drones his position is conditional rather than negative. "Everybody loves drones. You hear all kinds of stuff about drones, but are they realistic? It depends on the use case that you're trying to solve." His own experience using drones for RFID-based trailer location was mixed, because outdoor deployment carries constraints that indoor operation does not, and a single variation can invalidate a whole cycle count.
His reframe is the useful part. Drones may be the wrong tool for locating trailers and the right one for a different question: "Maybe locating your trailers isn't it, but maybe understanding is a human in the yard, or is something happening in the yard that shouldn't be, that might be a better use case."
The same logic extends to sensing generally. One camera network can serve several jobs at once. "Why not at the same time be able to provide perimeter security, or be scanning the sides of the trailer and identifying, hey, that gash wasn't there when it came in. So obviously it happened here. Let's play back what happened to that trailer or around that trailer."
That is the argument for infrastructure over point solutions, and it is what makes the sensing investment defensible before any autonomous vehicle shows up.
A Readiness Checklist
Work through these in order. Each is a prerequisite for the next.
Can your gate complete a check-in with no human in the vehicle? If not, this is the blocker, and it arrives first.
Is your inbound documentation machine-readable at the detail level, or only at the transaction level? An EDI message confirming a shipment exists is not the same as the data needed to route a driverless vehicle to a specific door.
Do you have network coverage across the yard, not just the building? Autonomous movement requires continuous communication outdoors.
Can your dock infrastructure report its own state? Restraints, doors and levellers need to be queryable, not just visible.
Do you know where every trailer is right now, without a person walking the yard? An autonomous vehicle cannot be routed to an asset the system cannot locate.
Can your system handle a mixed fleet indefinitely? Not as a transition phase, but as the permanent condition.
Most facilities fail at step one, which is useful, because step one is also the step with a clear return on its own regardless of what happens with autonomy.
What an Operating System Has to Do About It
The through-line of every prerequisite above is that they are integration problems, not vehicle problems. Something has to hold the context.
Brumett describes the requirement as a shift in what the software is for. "It's no longer just managing the assets. It's more about understanding the context of all, not only the assets, but all of the other things that interact with the assets. And that's really the purpose of an operating system: to orchestrate those different components so that they know how to interact together, they understand the context of why they're here, but also enable them to work together."
That is the case for a Yard Operating System rather than a yard management system, and it is a more concrete argument than the usual positioning. A YMS records where assets are. What an autonomous arrival needs is something that can tell a machine what to do next, in a context that includes the dock, the shipment, the restraint and the six other vehicles currently moving.
None of this requires buying autonomy today. It requires not building a gate process that will have to be replaced the first time a driverless truck arrives at it.
Frequently Asked Questions
Can autonomous trucks operate in a distribution yard today? Generally not without human intervention. Autonomous vehicles handle mapped point-to-point routes well, but yards are unmapped, highly variable environments, and conventional gate processes require a person in the cab to exchange documentation and receive direction. The vehicle is usually less of a constraint than the facility.
Why is a yard harder for autonomy than public roads? Public roads are mapped, standardised and heavily driven, so autonomous systems have extensive models of them. Yards are unmapped, change layout continuously with volume, contain mixed traffic, and require manoeuvres such as reversing a 53-foot trailer into a dock that have no equivalent in passenger driving.
What is a heterogeneous fleet and why does it matter? A heterogeneous fleet is the mix of different carriers, equipment types and technology levels arriving at a facility, from single owner-operators to large asset-owning fleets. It matters because facilities cannot assume uniform vehicle capability, so yard systems must handle autonomous and conventional arrivals simultaneously and indefinitely.
What infrastructure does a yard need before autonomous vehicles? Network coverage across the outdoor yard rather than just the building, sensing on dock infrastructure such as restraints so equipment can report its own state, real-time trailer location so vehicles can be routed to assets, and a gate that can complete check-in without a human in the vehicle.
Are drones useful in yard operations? Conditionally. Using drones to locate trailers has proven difficult outdoors, where environmental variation can invalidate a cycle count. They may be better suited to security and situational awareness, such as detecting unauthorised presence, than to inventory tasks.
Where to Start
Autonomy readiness and gate efficiency are the same project. The work that makes a facility ready for a driverless arrival is the work that reduces dwell today, which means it does not require a bet on a timeline.
Terminal's Yard Operating System provides the orchestration layer described here, with gate automation and yard visibility as the foundational modules. See the agentic AI yard for how the orchestration layer works, or explore the platform and walk through gate automation yourself with no sales call.
This article draws on Lights-Out Yard Episode 3 with Chris Brumett, Chief Product Officer at Terminal Industries.


